Nivek 4 Mini Mars Rover
Skills
- PIC24 Microcontroller
- MPLAB X IDE
- Coding in C
- PCB Design
- Sensor Integration
- Motor Control
- Circuit Design
- Embedded Programming
- Mechatronics
- Problem Solving
- Advanced debugging
- State machines
- SolidWorks (CAD)
- PID control
- Hands-on prototyping
Problem
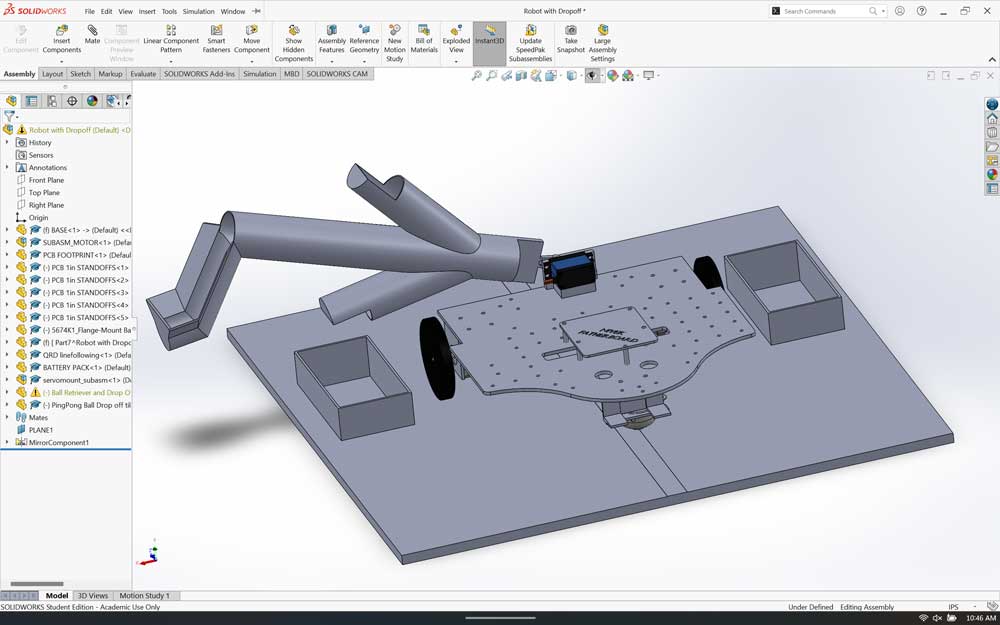
The objective of this project was to create a robot that can autonomously follow a line, traverse a “canyon,” collect and deposit a “sample,” and “connect” to a “satellite”. It has to complete all of these tasks consecutively without human interference or restarting.
Solution
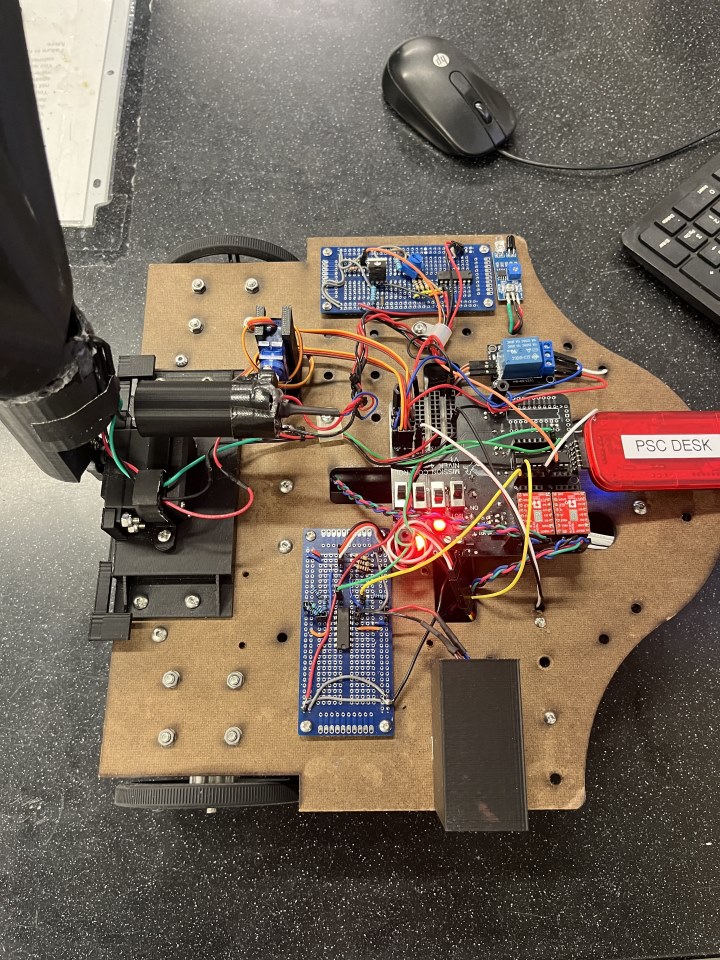
My team designed and built a custom mechatronic system integrating a PIC24 microcontroller, custom PCB, IR and distance sensors, QRDs, stepper and servo motors, MOSFETs, and custom mechanical hardware. Embedded C code coordinated sensing, motor control, state transitions, PID navigation, sample identification, and autonomous decision-making across the entire mission.
Basic Project Steps
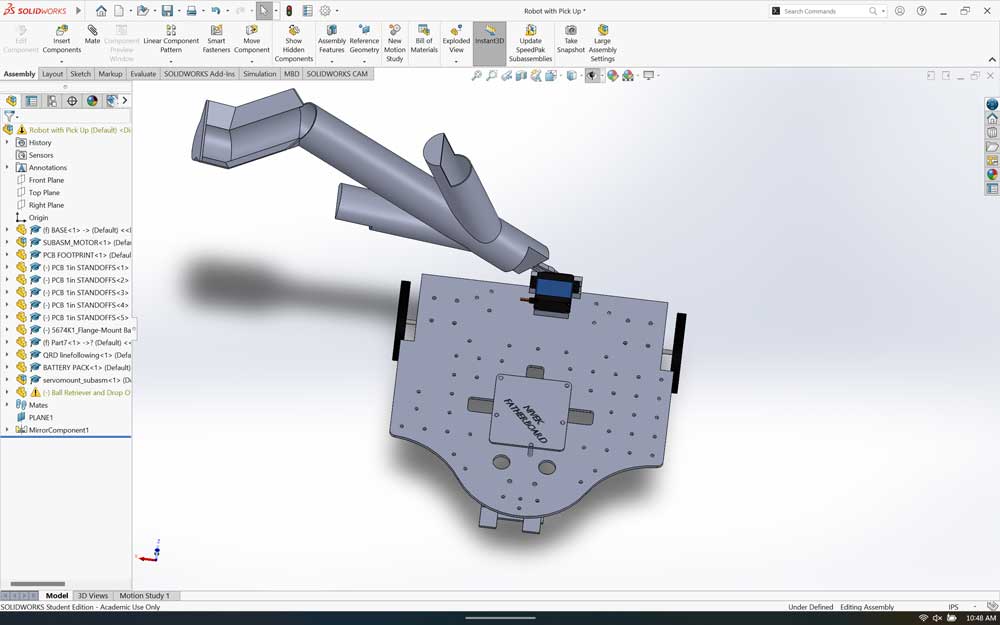
- Create a basic CAD model of the design
- Create the custom PCB
- Drive the motors
- Line follow
- Exit the lander correctly
- Develop PID control
- Navigate the “canyon”
- Detect IR light for sample pickup
- Detect sample color
- Detect sample drop-off and which bin to drop it off depending on the color
- Reenter the lander
- Detect the “satellite” and shine a laser on it to “send data”
Testing
This was a very intensive project that required some of the most testing that I have ever done for a single project. The required testing taught me how to efficiently recognize and diagnose problems. It strengthened my intuition skill in mechatronic systems, where failure points typically occur, and how to develop systems in a way that makes testing and solving problems easier. I learned how to keep detailed notes in code, make small changes to make diagnosing problems easier, and how to manage wiring to be easy to check.
Outcome
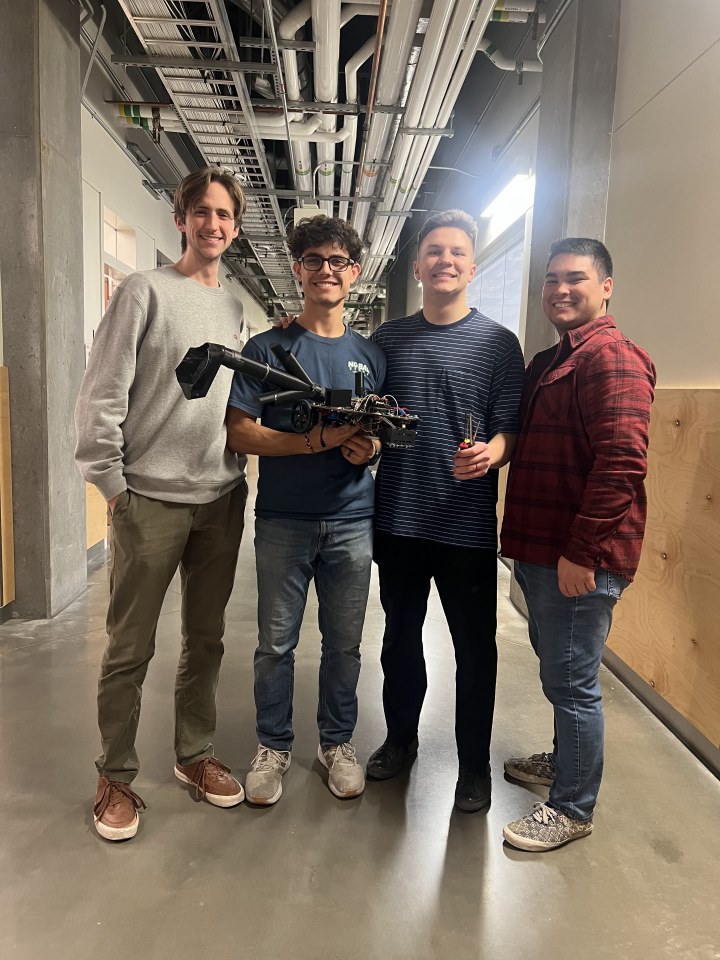
This is one of my favorite projects ever. There was a restriction that no AI could be used, so all of the code was done with our group's knowledge. This made having a successful rover a lot more gratifying and has greatly increased my coding competency and faith in my coding ability. I also received great satisfaction in rapid prototyping to find solutions and trying lots of potential options to find success. This project was completed and accomplished all of its design features. This has grown my love of mechatronic systems and is why I have started personal projects such as the robotic arm that sorts colored blocks and my little RC car. This was a grueling project and probably the one I am most proud of.